In order to provide N-D kriging, we should think about, what rotation and anisotropy means in higher dimensions.
My proposal is:
Rotation
-
in N-D we can describe rotation with M angles:

where M is the number of 2D sub-spaces (from main axis):
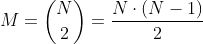
-
each angle describes the rotation in the x_i-x_j sub-space where the indices are given in the following order:

-
the rotation-matrix for a given angle in the i-j plane is given by:

-
consequently, the rotation matrix to bring unrotated coordinates into the desired rotation is given by:

-
since we are interested in derotating given points, we calculate the derotation matrix with:

Anisotropy
Anisotropy is given by N-1 anisotropy factors
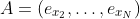
We can also formulate a transformation matrix by:

normalized lag
The normalized lag (Isotropified and derotated) is now given by:

Conclusion
The proposed formulation coincides with the current descriptions of rotation and anisotropy in 1D (none), 2D (rotation in x-y plane, 1 aniso-factor) and 3D (Tait–Bryan angles, 2 aniso-factors) and generalizes them to N-D.
What do you think? @rth, @bsmurphy, @LSchueler

In order to provide N-D kriging, we should think about, what rotation and anisotropy means in higher dimensions.
My proposal is:
Rotation
in N-D we can describe rotation with M angles:

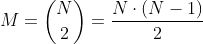
where M is the number of 2D sub-spaces (from main axis):
each angle describes the rotation in the x_i-x_j sub-space where the indices are given in the following order:

the rotation-matrix for a given angle in the i-j plane is given by:

consequently, the rotation matrix to bring unrotated coordinates into the desired rotation is given by:

since we are interested in derotating given points, we calculate the derotation matrix with:

Anisotropy
Anisotropy is given by N-1 anisotropy factors
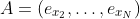
We can also formulate a transformation matrix by:

normalized lag
The normalized lag (Isotropified and derotated) is now given by:

Conclusion
The proposed formulation coincides with the current descriptions of rotation and anisotropy in 1D (none), 2D (rotation in x-y plane, 1 aniso-factor) and 3D (Tait–Bryan angles, 2 aniso-factors) and generalizes them to N-D.
What do you think? @rth, @bsmurphy, @LSchueler